An autonomous robot is blind without perceptual transducers. To build metric maps, estimate ego-motion, and interact with objects, spatial intelligence architectures fuse internal proprioceptive sensors (measuring joint positions and internal body accelerations) with external exteroceptive sensors (measuring ambient spatial geometry). Among 3D range sensors, LiDAR Time-of-Flight and RGB-D structured light cameras serve as the perceptual eyes of autonomous vehicles, mobile manipulation arms, and humanoid robots.
1. LiDAR: Direct Time-of-Flight (dToF) vs. FMCW
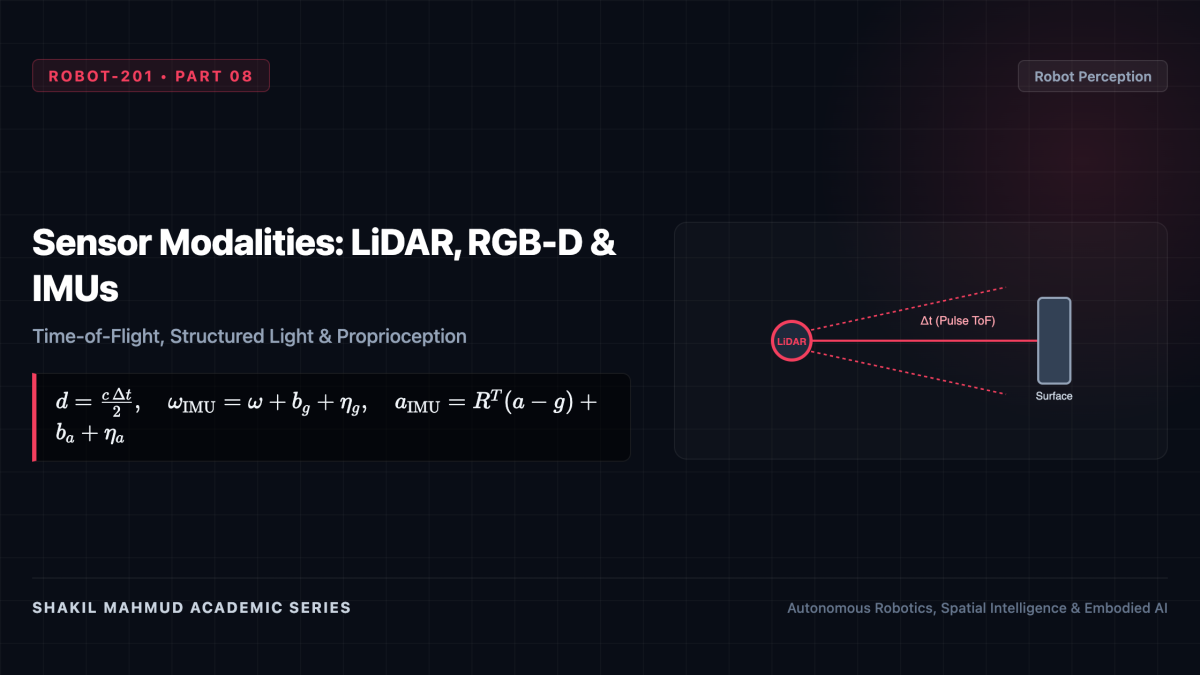
Light Detection and Ranging (LiDAR) generates dense, millimeter-accurate 3D point clouds by firing near-infrared laser pulses ((lambda approx 905 ext{ nm}) or (1550 ext{ nm})):
- Direct Time-of-Flight (dToF): A laser diode fires a nanosecond optical pulse. A Single-Photon Avalanche Diode (SPAD) detector times the round-trip arrival (Delta t):
[
d = rac{c cdot Delta t}{2}
]
Multi-beam mechanical spinning LiDARs (e.g., Velodyne, Ouster) or solid-state optical phased arrays generate millions of georeferenced ((x, y, z, ext{intensity})) points per second up to (250 ext{ meters}). - Frequency Modulated Continuous Wave (FMCW) LiDAR: Emits a continuous, linearly chirped frequency waveform (f(t) = f_0 + alpha t). Mixing the returned reflection with a local oscillator yields a beat frequency (Delta f_{ ext{beat}}) that simultaneously reveals both range (d) and instantaneous Doppler velocity (v_{ ext{radial}}) per pixel in a single shot.
2. RGB-D Cameras: Structured Light and Stereo Disparity
For indoor manipulation and human-scale perception within (0.5 ext{–}5 ext{ meters}), robots utilize RGB-D cameras (e.g., Intel RealSense, Orbbec, Microsoft Azure Kinect):
- Active Structured Light: An infrared projector casts a pseudo-random speckled diffraction pattern across the scene. An off-axis CMOS infrared sensor detects spatial deformations in the pattern, computing depth (Z) from pixel disparity (d = x_L – x_R):
[
Z = rac{f cdot B}{d}
]
Where (f) is the focal length in pixels and (B) is the baseline distance between projector and sensor. - Active Stereo Infrared: Two calibrated IR sensors observe the projected pattern simultaneously, eliminating ambient lighting sensitivity and delivering synchronized color RGB frames aligned with dense depth maps.
3. Inertial Measurement Units (IMUs) and Allan Variance
Proprioceptive navigation relies on 6-DoF MEMS Inertial Measurement Units (IMUs) comprising a 3-axis triaxial accelerometer and a 3-axis angular rate gyroscope:
[
omega_{ ext{raw}}(t) = omega(t) + b_g(t) + ta_g(t), quad a_{ ext{raw}}(t) = R^T(t) left( a(t) – g
ight) + b_a(t) + ta_a(t)
]
Where:
- (ta(t) sim mathcal{N}(0, sigma^2)) is high-frequency additive white Gaussian measurement noise (Angular/Velocity Random Walk).
- (b(t)) is the slow bias drift modeled as a Brownian random walk: (dot{b}(t) = ta_b(t)).
- Double integration of uncalibrated accelerometer readings ((p(t) = iint a(t) dt^2)) causes position drift to diverge quadratically with time ((mathcal{O}(t^2))).
Roboticists characterize IMU noise parameters using Allan Variance Analysis, identifying white noise, bias instability, and rate random walk regimes to tune Kalman filter covariance matrices.
4. Spatial Multimodal Extrinsic Calibration
To fuse data from a camera, a LiDAR, and an IMU mounted on different links of a robot, their spatial transformation matrices (T_{ ext{cam}}^{ ext{lidar}}, T_{ ext{imu}}^{ ext{cam}} in ext{SE}(3)) and temporal time offsets (Delta t_{ ext{sync}}) must be rigorously calibrated.
By observing a planar checkerboard or AprilTag calibration target across multiple viewpoints, non-linear batch optimization minimizes the combined 2D reprojection and 3D point-to-plane residual errors:
[
min_{T, Delta t} sum left( |x_{ ext{pixel}} – pi(T_{ ext{cam}}^{ ext{lidar}} P_{ ext{lidar}})|^2 + ext{IMU preintegration residuals}
ight)
]
Achieving sub-millimeter extrinsic accuracy and sub-millisecond temporal synchronization unlocks real-time Visual-Inertial-LiDAR Odometry (VILO) for agile spatial navigation.